- New
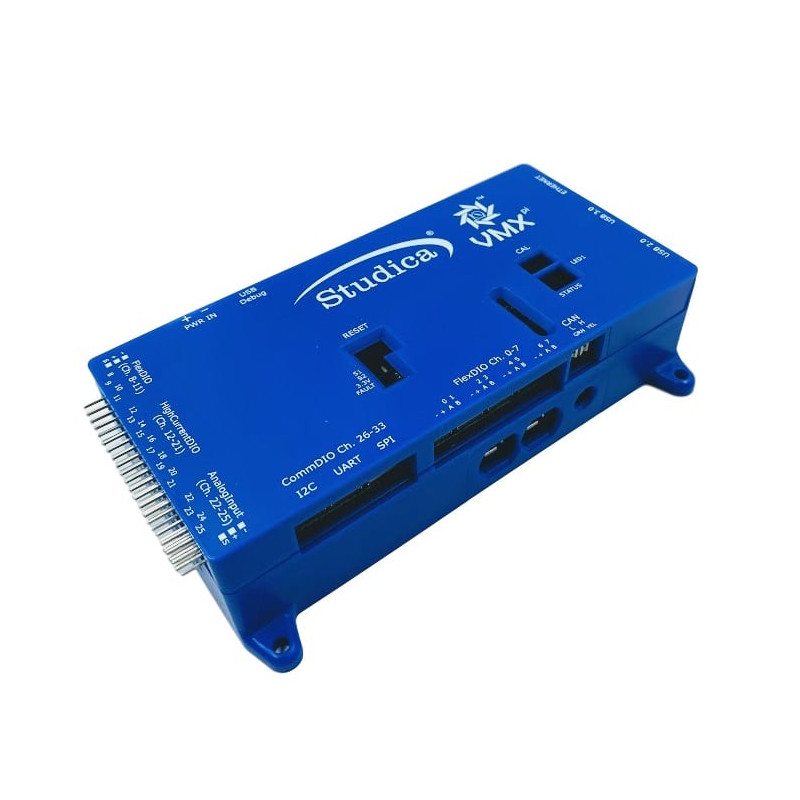

This latest version of the VMX is the VMX2, a powerful robot controller, Enables Tele-op and autonomous control Programmable in Java, C++, Python, LabVIEW, and ROS Integrates the navX-IMU, a Linux based controller, Gigabit Ethernet, USB3 ports and built-in Wifi/Bluetooth.
This latest version of the VMX is the VMX2, a powerful robot controller,
The VMX2 leverages five advanced key technology developments,
The Studica VMX2 Technology Enables,
The VMX2 circuit board and official firmware provide inertial and magnetic measurements, with a range, accuracy and update rate as described on this page, as well as a broad range of I/O and Digital Communication capabilities and flexible Power Management.
Note that certain IMU performance specifications are only valid after a start-up Gyroscope/Accelerometer Calibration period, during which time the VMX-pi circuit board must be held still.
Additional details can be found in the VMX Datasheet.
Additionally, the specifications for the connector cables with come with each VMX are also documented on this page.
| ELECTRICAL SPECIFICATIONS | |
| Input Voltage: | 6-16V DC |
| Output Voltages: | 5V, 3.3V |
| Protection Features: | Input Voltage Clamps; Under-voltage management; Output Current Limiting |
| Communications Interface: | USB, I2C, SPI, CAN,UART |
| Power Connector: | 2-Pin JST VH Connector |
| USB Connector: | USB Micro-B |
|
IMU PERFORMANCE SPECIFICATIONS |
|
| Startup Calibration Period: | 15 seconds |
| Gyro Sensitivity: | +/- 2000 degrees/sec |
| Accel Sensitivity: | +/- 2 g |
| Magnetometer Sensitivity: | 1.3 Gauss |
| Yaw angle accuracy: | ~1 degree of drift/minute |
| Yaw angle accuracy (when still): | ~.25 degree of drift/minute |
| Orientation Data Update Rate: | 4-100 Hz |
| Magnetometer Raw Update Rate: | 4 Hz |
| Magnetometer Angular Accuracy: | +/- 2 degrees |
| Pitch/Roll Angular Accuracy: | +/- 1.5 degrees |
|
ANALOG INPUT SPECIFICATIONS |
|
| Number of Channels: | 4 |
| Resolution: | 12 bits |
|
DIGITAL IO SPECIFICATIONS |
|
| Total Number of Channels: | 30 |
| Number of Input-capable & Interrupt-capable Channels: | 25 |
| Number of Output-capable & PWM-capable Channels: | 27 |
| Number of Quadrature Encoder Channel Pairs (HW-decode): | 5 |
|
DIGITAL COMMUNICATION SPECIFICATIONS |
|
| CAN Protocol (2.0b) | 1mbps |
| SPI Protocol | 8 Mhz |
| I2C Protocol | 400 kHz |
| USB Protocol | 12 mbps |
| UART Protocol | 115 kbps |
This latest version of the VMX is the VMX2, a powerful robot controller, Enables Tele-op and autonomous control Programmable in Java, C++, Python, LabVIEW, and ROS Integrates the navX-IMU, a Linux based controller, Gigabit Ethernet, USB3 ports and built-in Wifi/Bluetooth.